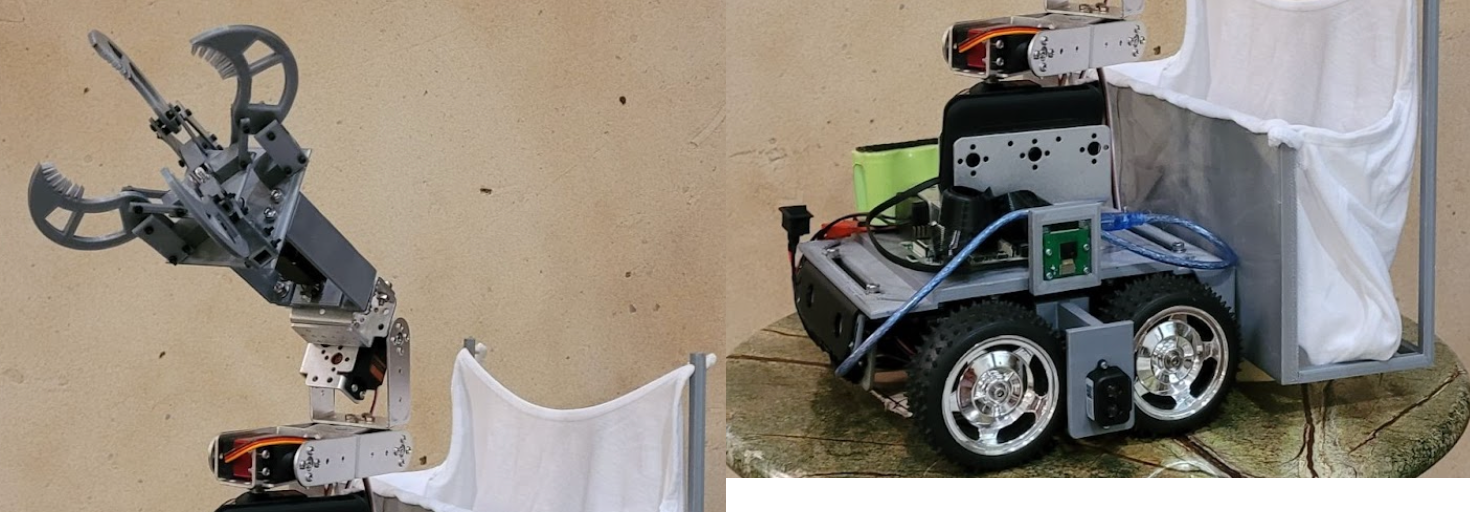
BEET autonomous robot
Contributed to a cotton-harvesting robot, training a TensorFlow image classifier and deploying a TFLite model on a Raspberry Pi.
2022 ASABE team awards: second in engineering design and first for project poster.
My projects span electronics, robotics, and machine learning, from autonomous robots to community irrigation systems.
I enjoy working across hardware and software, and bringing engineering into community projects.
Contributed to a cotton-harvesting robot, training a TensorFlow image classifier and deploying a TFLite model on a Raspberry Pi.
2022 ASABE team awards: second in engineering design and first for project poster.
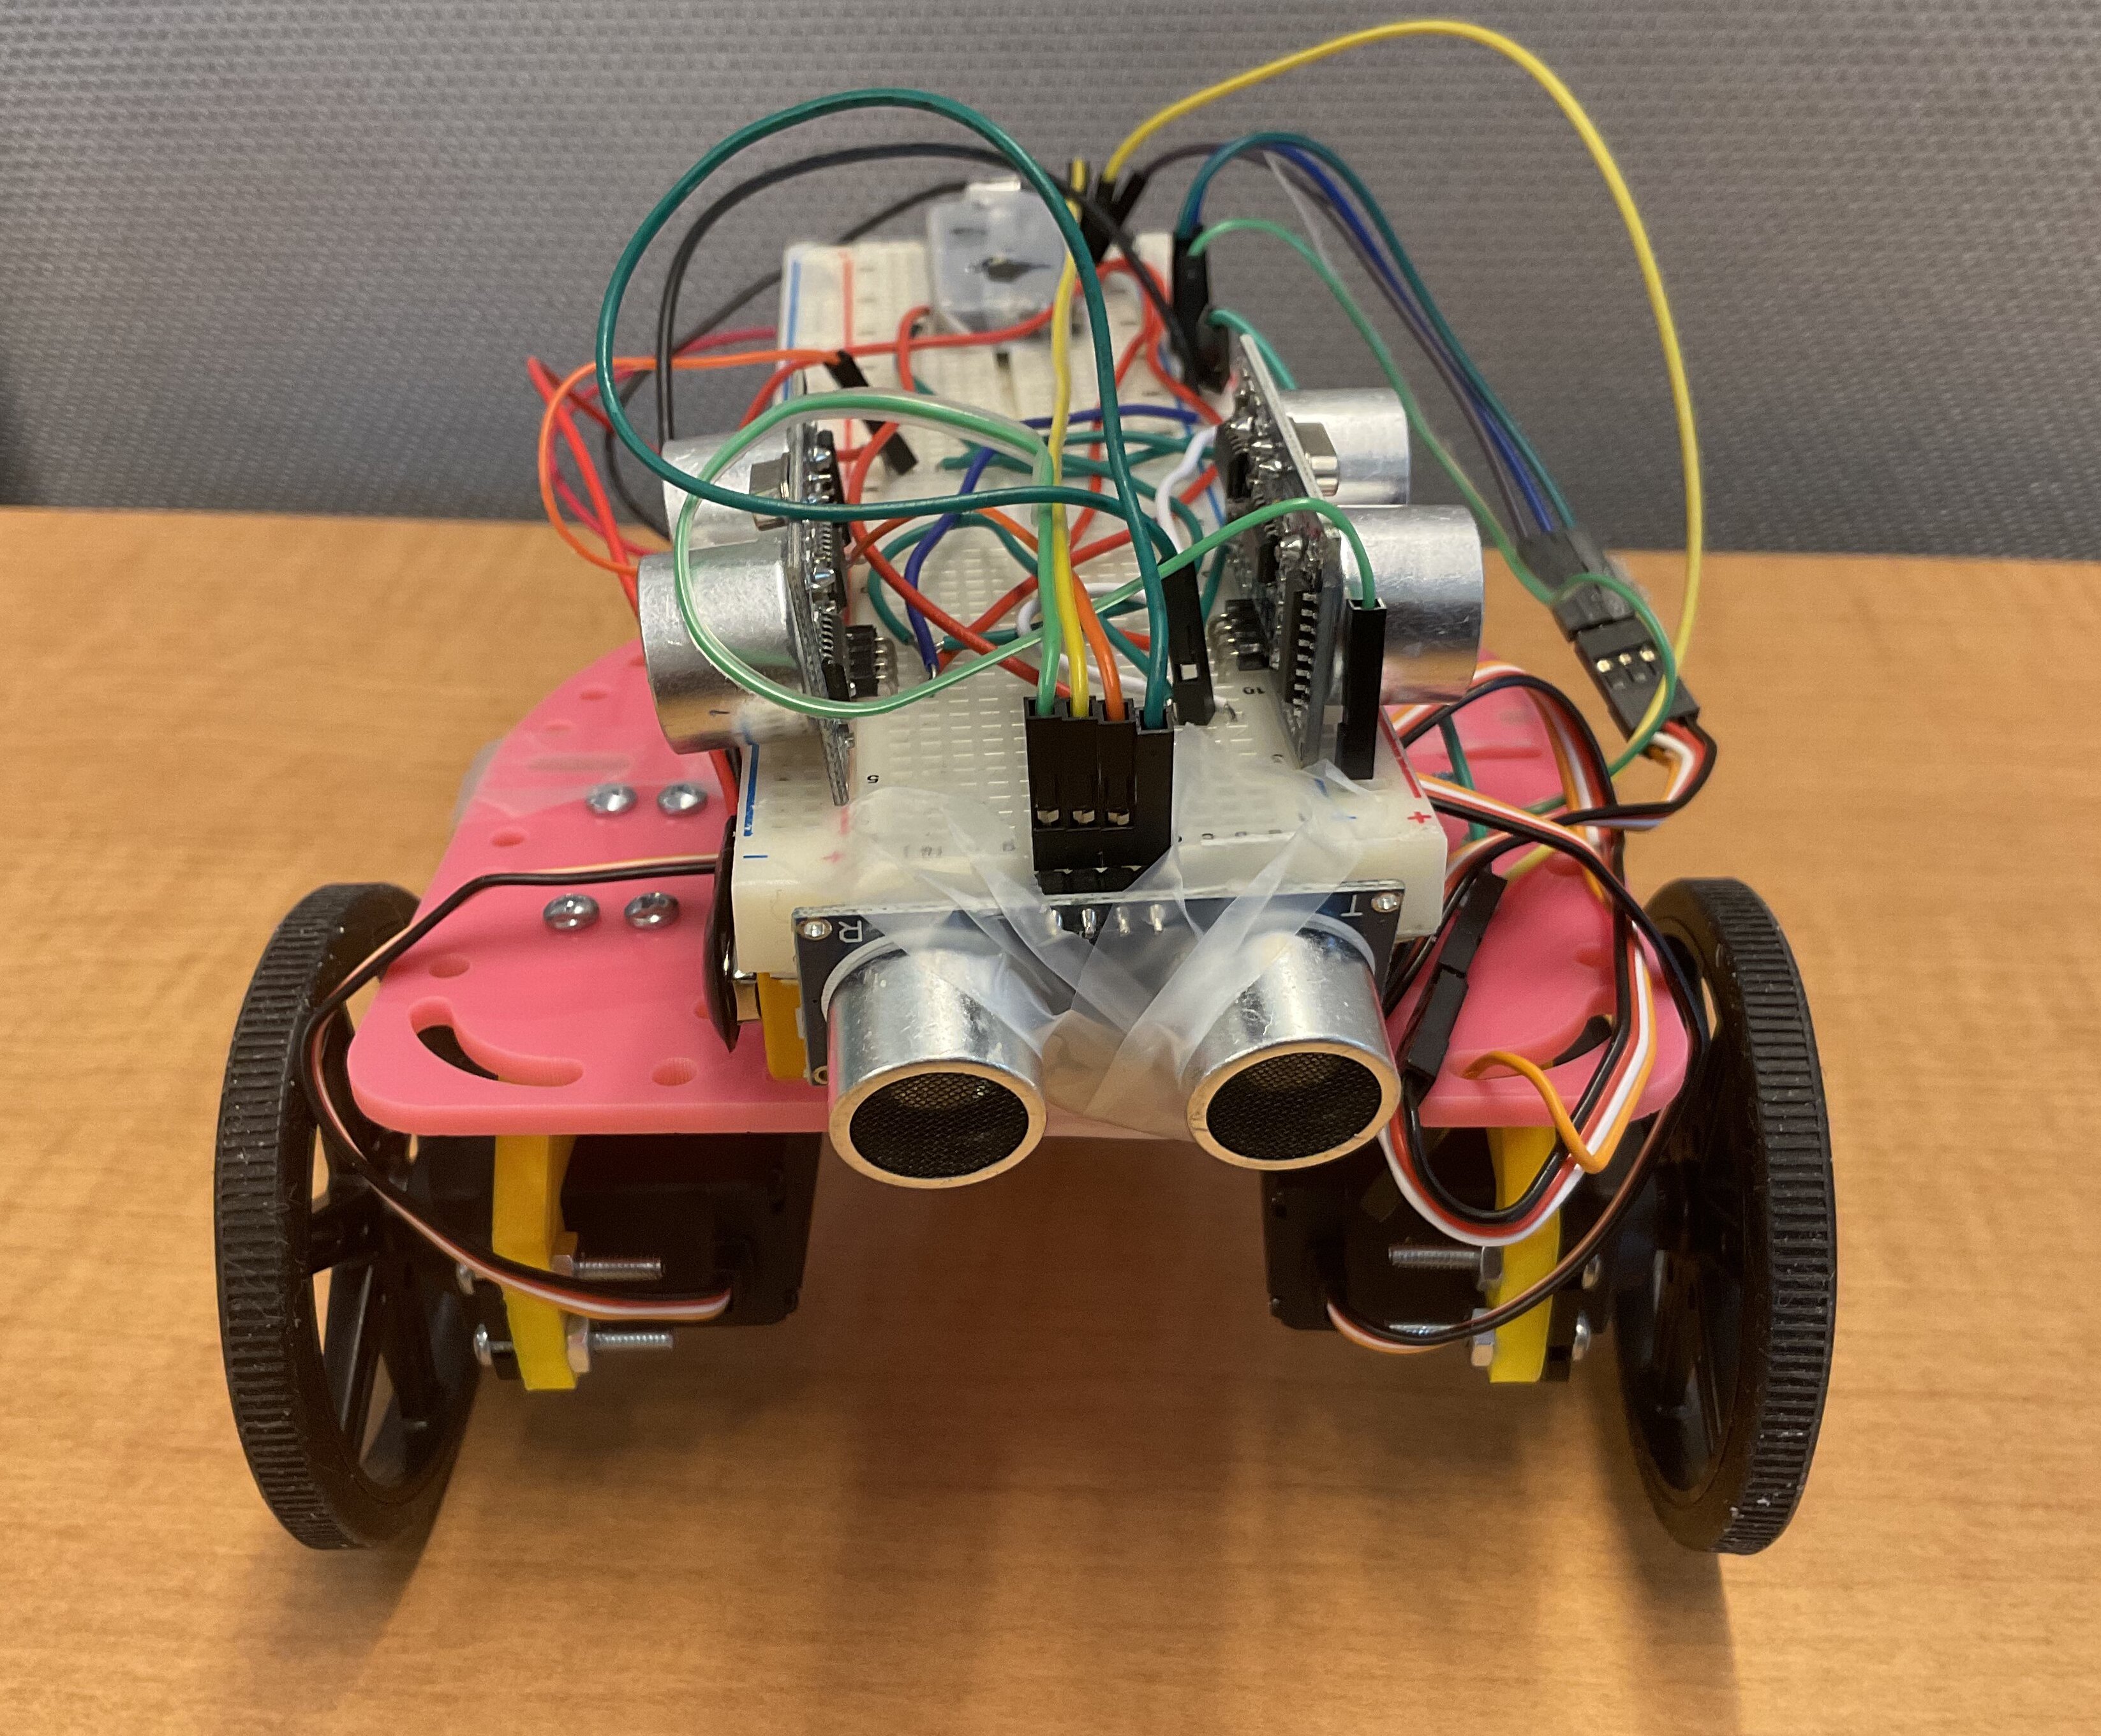
Programmed a robot car in C to navigate a maze using ultrasonic sensing, an Arduino Nano, and infrared detection.
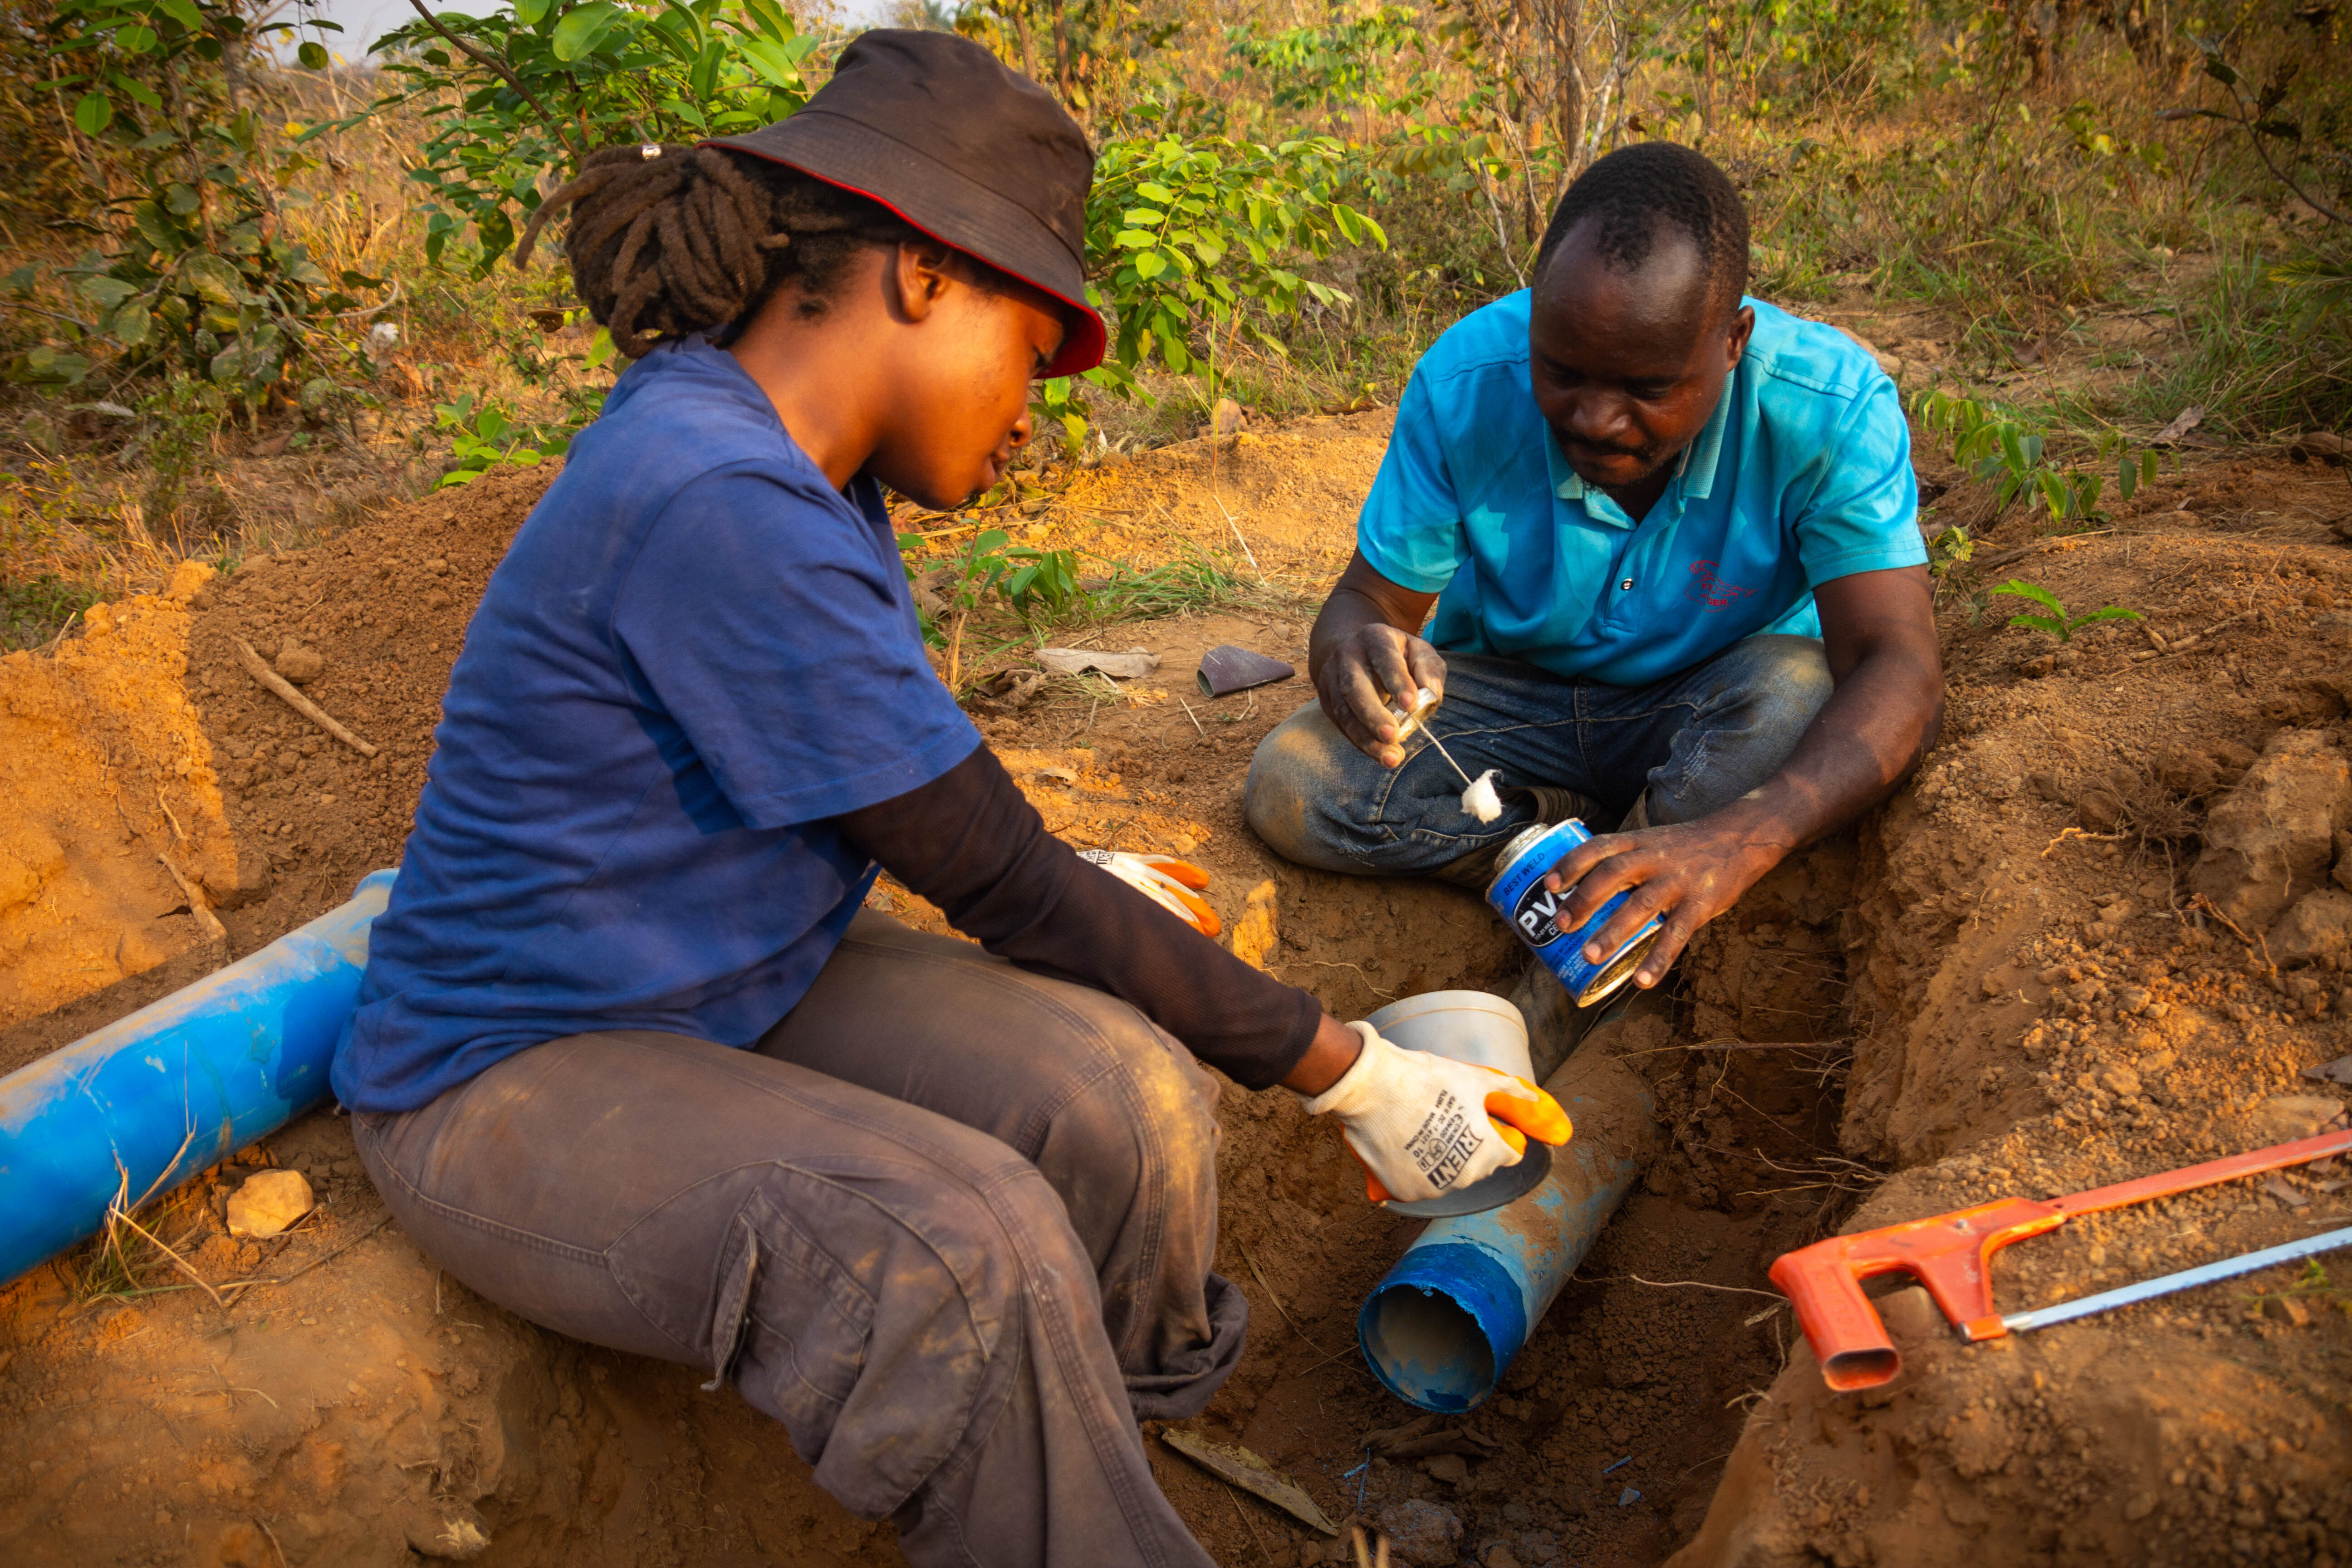
Worked with Engineers Without Borders, local contractors, and community partners on ferrocement water tanks for an irrigation system in Tanzania.
July–August 2023
Undergraduate researcher, Personal Robotics Lab
Helped develop a shared-control power-wheelchair system using Python, ROS, and CAN communication.
January–June 2023
Software Development Engineering Co-op
Trained and evaluated image-recognition models and deployed TFLite models to autonomous mobile robots.
January–May 2022
Mechanical Engineering Intern
Designed and modeled an autonomous vegetable-cutting mechanism using Fusion 360.